Coursework for modules "Technical Art Application" and "Scripting and Dynamics" at the University of Abertay Dundee.
Intellectual property of Zoe Sams.
After my last dilemma I've decided to stick with the model I have and implement facial features onto it anyway, even if the mesh isn't fantastic. I've created two, untextured spherical eyes two put into the mesh so that I can move them separately and added all joints and control shapes into the face. I've also added a "face" controller, which holds attributes for different expressions and mouth shapes such as "ooh" and "eee".
There are a few things I would like to edit now though, as when the head controller is moved the features don't follow it. However if I add a parent constraint to those controllers, the mouth shape attributes no longer work. Will need to investigate ways round this. My shoulder controllers have also stopped working so will need to re-attach them at some point soon
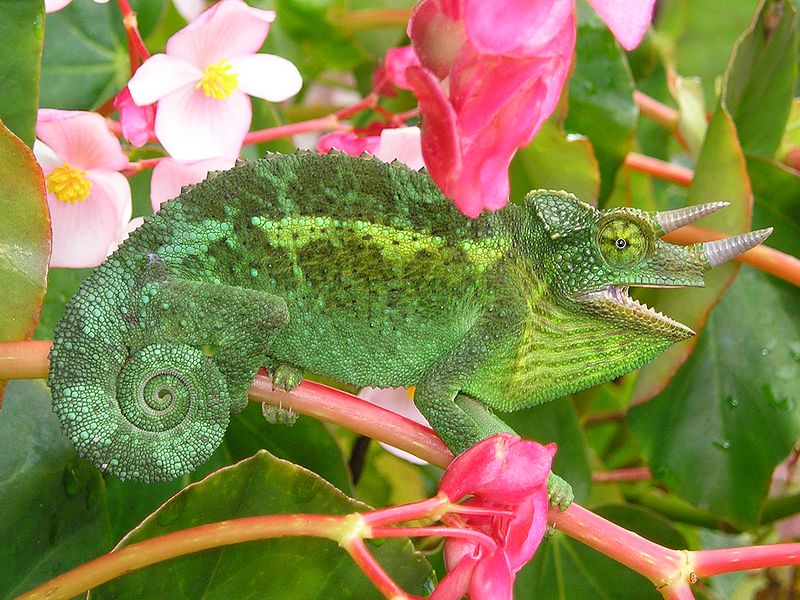
After casually discussing my project with a friend who is studying animal biology, I've decided to research lizards. She explained to me that most lizard tails don't actually curl into a perfect spiral - only really the Chameleon can curl it's tail in such a way.
Now that I've begun researching this tail movement I've decided to focus my rig more on the gecko. Gecko's tails tend to flail when they're hunting, and additional movements tend to be swinging the tail ever so slightly side to side when the character walks. As far as a curl goes, I believe my rig still isn't quite correct and I may need to add in more joints to the tail to create a smoother curve. However I don't want to over-do it as my joint count is currently at 54 and I haven't yet added in the joints for the face. 72 is the max joint count for UDK for games so I'd like to keep my rig under this, meaning I have around 16 joints for the face and 2 more that I could add into my tail.
This would be: 2 in each eyebrow, 1 for each eye, 1 for each eyelid, 1 for each corner of the mouth, 1 for the upper lip, 1 for the lower lip, 1 for each cheek.
HOWEVER. Again. I've just noticed my mesh doesn't have eyelids. Or even a gap for eyes. Just two semi-sphere's stuck on the front of the face. And in fact the face in general doesn't have much geometry to work with. This either makes my job a lot easier, or a lot harder... I'm either going to have to find a different rig, or create the gaps for eyes myself and just accept the rest of the face as is. This day has turned out to be much more complicated than expected.
Tail does not curl as I would want it to, this may be a problem
because of something I have done or just the way the IK works
Now that the control shapes in my rig all have a function, I've been trying to work out if each function works in the way I want it to. For instance, at the moment I have a spline IK in my tail, however it doesn't move or curl quite how I want it to. I'm going to look into either increasing the number of spans I have in the IK, or a different method entirely and have attributes controlling the curl and swing, much like the use of the fingers. I do however like the way the tail sits with a Spline IK, as when I lower it to "ground level" it gives a lovely curve.
Apart from that most other shapes move well, and I've begun adding in multiple attributes for the fingers and feet. By next week I'd like to have all these major decisions finalised, the extra attributes adding in and functioning properly, and begin work on the facial joints. After this is all completed I should hopefully be able to begin skinning the week before Christmas.
UPDATE: I also forget to mention that I managed to fix the problem with my orient constraints on my wrists, it appears I had just been working on it too long and over-looked a small mistake.
Displaying one wrist orient joint correctly rotating
Now that I've finished the basic skeleton and control shape set up in my rig, I am now beginning to add functionality to each control shape but am having some problems with this.
Though my legs have their IK handles and pole vector constraints set up and working perfectly, the arms seem to be misbehaving slightly. I have the orient constraint on one of my wrists working well when connected to the pole vector constraint for the elbow however the other seems to have some sort of odd movement which twists the whole arm. I believe I may have just mistakenly missed out a step and will come back to it tomorrow with fresh eyes to see if I can work out what I've done wrong.
Now that my basic skeleton is set up, I can start adding in control shapes and working out which IK's I should use to get the functionality that I want for each group of joints.
After finally founding a model to work with (or more, settling with one I found right at the beginning of my search) I've started to do some research into how lizards move in the wild to see if maybe I can connect aspects of this to my rig.
After investigating I've found some lizards, such as the chameleon, curl there tail in towards there back legs rather than up towards there spine, however others lock once they get between their legs and only curl towards their back like I first planned the functionality of my rig. I think I'd like to stick with my original idea, as I believe it would work better on a standing figure rather than having a tail tucked between the legs. I also investigated the way lizards facial expressions move, and thought about the wide range of movements on the eyes of lizards, however my rig does have a slightly more human face and although I'm going to put more effort into the eyes than originally thought, I won't be adding in extra functionality.
Over the next couple of days I'd really like to focus more on research to see what added features a lizard has that I can implement into my rig, and start focusing on the actual rigging again by the start of next week.